NVIDIA Isaac ROS 5.0 combines a robotics-stack upgrade with a new development method: AI coding agents can use purpose-built skills to help migrate nodes, while ROS messages can keep large payloads on the GPU when compatible endpoints support the CUDA buffer backend.
What ships in NVIDIA Isaac ROS 5.0
NVIDIA Isaac ROS 5.0 moves the accelerated robotics stack to ROS 2 Lyrical, adds an Isaac ROS Buildfarm apt repository and introduces AI agent skills in an open Agent Skills format. The initial skills help activate the development environment and assist with migration workflows.
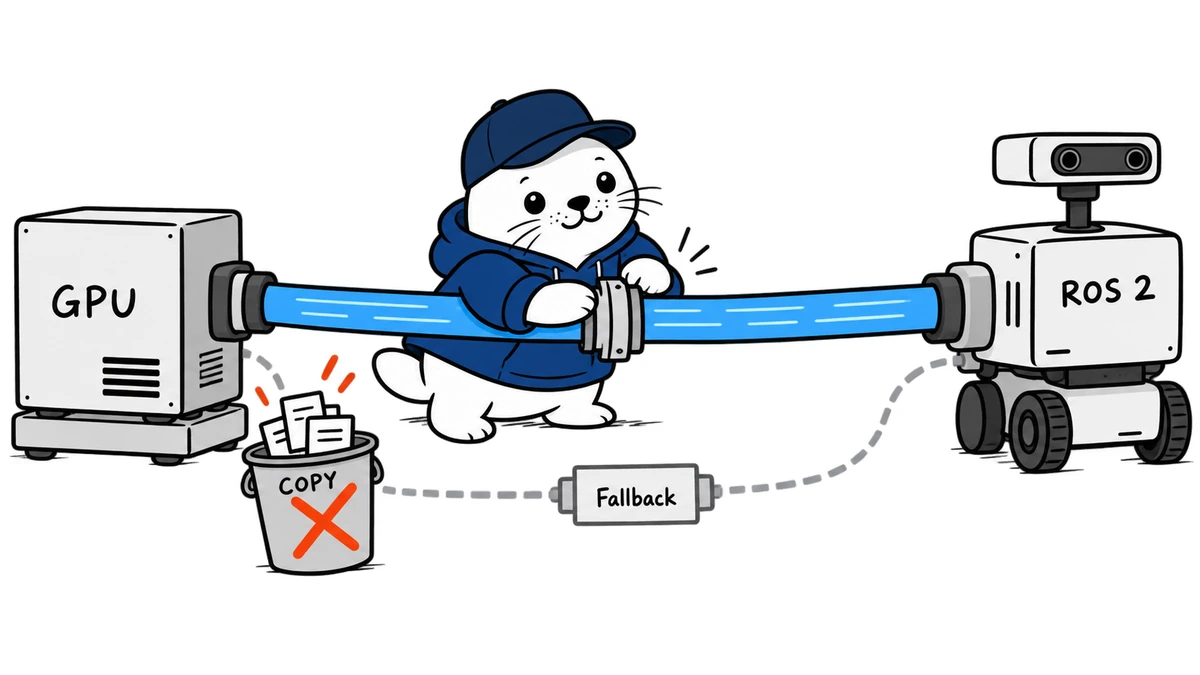
The release also updates Isaac ROS nodes to use rosidl::Buffer with a CUDA buffer backend. That change addresses an unglamorous bottleneck: a GPU-accelerated algorithm can still spend time copying messages through CPU memory between nodes.
The copy problem between fast nodes
A perception node may receive an image, run TensorRT inference on the GPU and publish a depth map to another GPU-capable node. If the ROS boundary serializes the payload into CPU-backed storage, the graph adds allocation, transfer and serialization work around an otherwise fast kernel.
rosidl::Buffer moves storage-backend handling behind a standard ROS 2 field. With NVIDIA’s CUDA backend, compatible publishers and subscribers can exchange GPU-resident payloads through zero-copy transport when runtime conditions allow.
What zero-copy does and does not mean
| Condition | Expected behavior | Verification |
|---|---|---|
| Both endpoints support the CUDA backend | Payload can remain in GPU-backed storage | Inspect backend type and transfer trace |
| A peer requires CPU memory | Fallback remains available through the standard message contract | Confirm the fallback path and cost |
| Algorithm is GPU-accelerated but message boundary is not | Host-device copies may remain | Use Nsight Systems to locate payload-sized transfers |
| Developer installs Isaac ROS 5.0 | No automatic guarantee for custom nodes | Audit and migrate each relevant boundary |
The agent skill is a migration assistant, not an optimizer oracle
NVIDIA demonstrates a migrate-node-to-rosidl-buffer skill. An AI coding agent uses it to inspect a CUDA-accelerated node, trace allocations and conversions, propose a minimal interface-preserving refactor and verify that the CUDA path is enabled.
The skill can make the audit repeatable, especially across a repository with many nodes. It cannot prove that the generated refactor is correct without builds, tests, hardware runs and transfer traces. Stream ownership, message lifetime and CPU fallback are precisely the details that require careful review.
A practical migration sequence
- Identify GPU-accelerated nodes that exchange large messages.
- Capture a baseline with representative sensors, rates and hardware.
- Trace allocations, serialization and host-device transfers at each ROS boundary.
- Use the migration skill on one node while preserving the standard message contract.
- Build and test both CUDA-backed and CPU-fallback paths.
- Check the reported backend type at runtime.
- Repeat the same Nsight Systems measurement and compare end-to-end latency, not only kernel time.
Compatibility should be documented per graph edge
A robotics graph is only as zero-copy as its participating endpoints. Cameras, visualization tools, recorders, custom nodes and remote transports may require different memory backends. Teams should document producer, consumer, backend and fallback behavior for every high-volume edge.
- Do not assume that an updated library migrates custom code.
- Keep fallback behavior deterministic and tested.
- Measure memory pressure as well as latency.
- Record the Jetson or GPU platform and software versions.
- Treat agent-generated changes like any other performance-sensitive patch.
How Isaac ROS 5.0 relates to the wider NVIDIA stack
Isaac ROS is the accelerated ROS package layer, while Isaac Sim provides simulation and synthetic-data workflows. Our Isaac Sim 6.1 migration guide covers its 11 agent skills and breaking changes. The TensorRT Edge-LLM benchmark analysis explains why edge performance claims need hardware, workload and measurement context.
The common trend is that NVIDIA is packaging operational knowledge as agent-readable skills. That can shorten setup and migration work, provided the resulting system remains testable without the agent.
The practical verdict
NVIDIA Isaac ROS 5.0 is notable for joining two improvements: a lower-copy data path and agent-assisted migration. The technical value comes from preserving a standard ROS 2 contract while allowing compatible nodes to keep payloads on the GPU.
Developers should not repeat “zero-copy” as a blanket release claim. Prove it at each graph boundary, preserve CPU fallback and use Nsight Systems to confirm that payload-sized host-device transfers have actually disappeared.
Primary sources
- NVIDIA Developer Forums: Isaac ROS 5.0 announcement
- NVIDIA Technical Blog: migrate a ROS 2 node with an AI agent
Checked September 23, 2026. Zero-copy behavior depends on compatible endpoints and runtime conditions. Performance improvements must be verified on the target graph and hardware.